
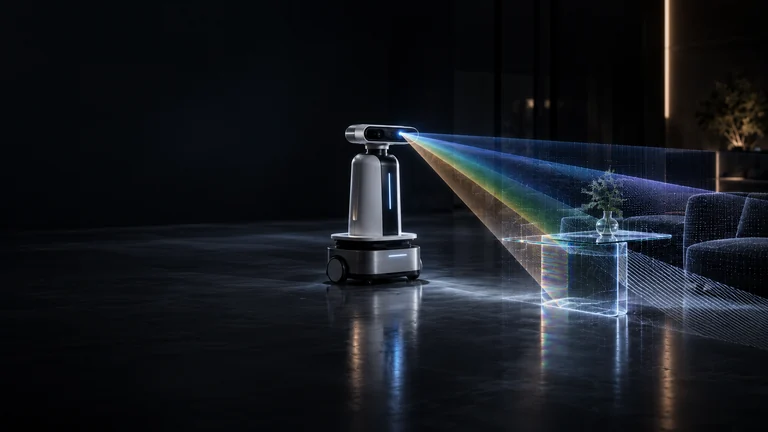
Transparent / Translucent
Inform boundary and surface estimation
Sense the physical world. Build machine understanding.
Spectrum · Polarization · 3D
Front-end computation and multimodal perception work together
to support robotic recognition and manipulation.
Inform boundary and surface estimation
Polarization adds surface cues
Spectra help distinguish materials
Depth adds geometric cues
VISUAL FOUNDATION MODEL
Shared visual representations for diverse tasks
01 Image input
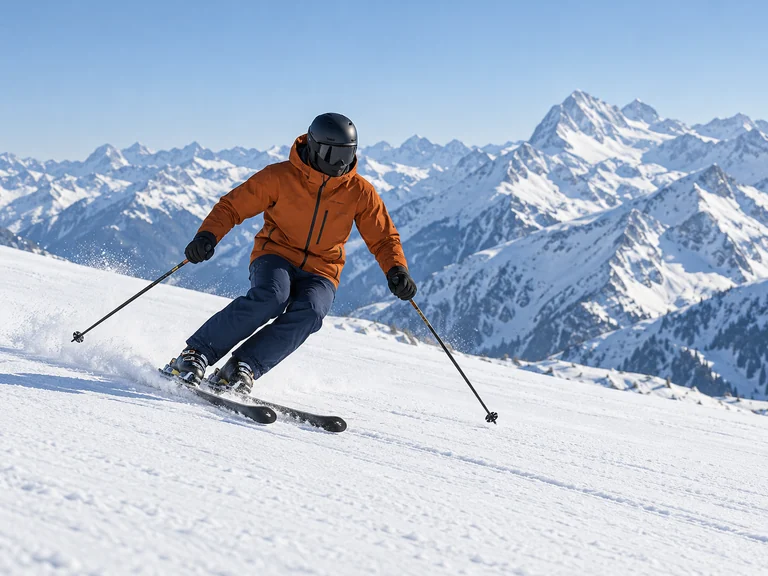
Visual task input
02 Visual representation
Shared visual understanding
03 Task adaptation and outputs
SkiingSkier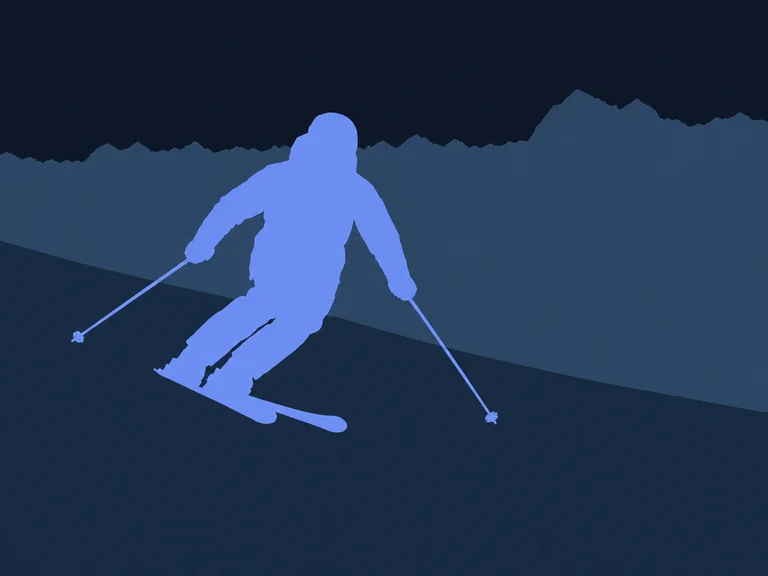
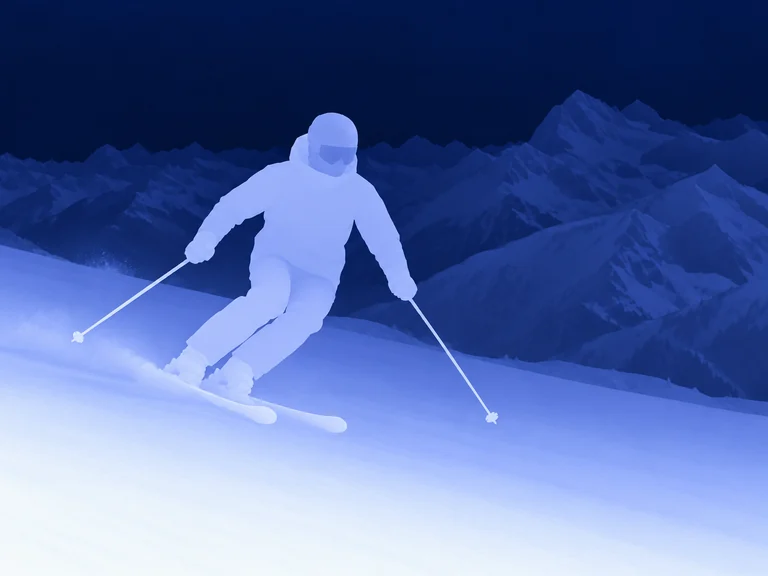
Image and task outputs are conceptual illustrations
CONTACT
Discuss your application, technical needs, and opportunities for joint validation.